Canine leash pulling represents an uncontrolled transfer of kinetic energy between a forward-driven mass and a human handler, creating a mechanical failure point in daily management. Standard back-clip harnesses and traditional collars do not suppress this dynamic; instead, they exploit an innate physiological response known as the opposition reflex, turning every forward stride of a dog into an amplified traction exercise. Resolving this issue requires dismantling the physical forces involved, altering the point of force application, and establishing a rigorous operational protocol that prioritizes vector redirection over brute-force restraint.
The Biomechanical Failure of Traditional Restraints
Traditional neck collars concentrate entire kinetic loads directly onto the trachea and cervical vertebrae. When a dog surges forward, the resulting pressure triggers a localized nociceptive response, yet the animal's forward drive frequently overrides discomfort due to adrenaline and environmental reinforcement. Standard back-clip harnesses exacerbate this issue by shifting the attachment point directly over the center of mass or the shoulder blades. Meanwhile, you can read similar stories here: The Ground Beneath Their Fingernails.
This dorsal positioning mimics the anatomical configuration utilized in drafting and sled-pulling sports. The canine nervous system interprets dorsal pressure as an invitation to lean into the harness, activating the pectoral and forelimb musculature to generate maximum horizontal propulsion. The handler is forced into a static tug-of-war, pitting human upper body strength against the animal's structural center of gravity. This dynamic creates a high-friction operating environment where equipment failure and human shoulder injury occur with high frequency. Repeated tension across the cervical or thoracic spine also risks chronic soft tissue inflammation, subclinical vertebral impingement, and long-term musculoskeletal degradation in working and companion dogs alike.
The Three Structural Architectures of Traction Mitigation
Modifying canine propulsion mechanics requires altering the point where tensile force enters the skeletal frame. Equipment designers utilize three distinct mechanical architectures to disrupt forward drive. To see the full picture, check out the recent report by ELLE.
Front-Clip Redirection Systems
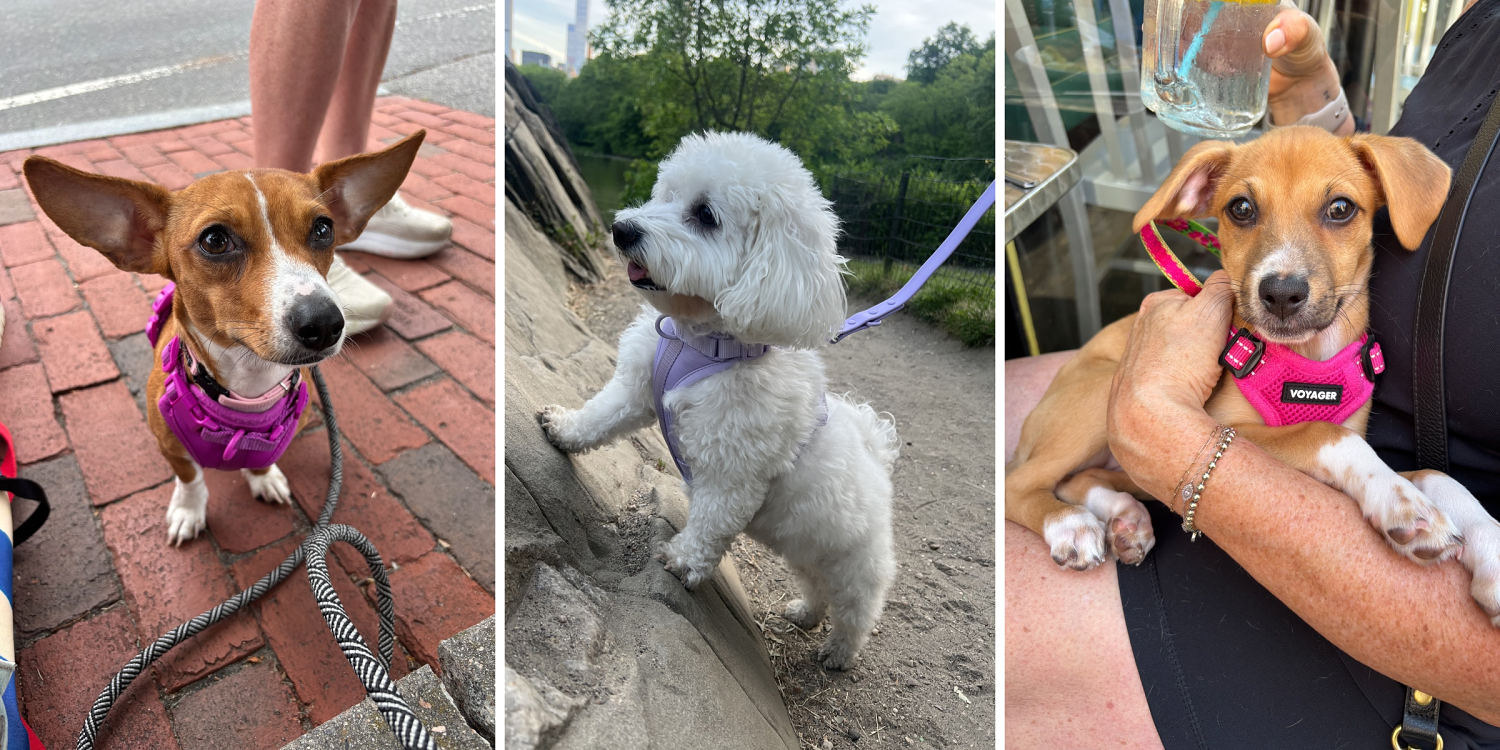
Front-clip harnesses position the leash attachment ring on the center of the sternum. When a dog wearing a sternum-attachment harness moves forward ahead of the handler, tension on the leash exerts a lateral rotational force rather than a linear pulling force. The animal's own momentum pivots its body toward the handler, instantly breaking the forward stride cycle. This redirection neutralizes the opposition reflex by removing the straight-line resistance vector. The animal quickly learns that forward surging yields zero forward progress, as kinetic energy is instantly converted into rotational turning force.
Dual-Clip Distribution Networks
Dual-clip configurations feature attachment points on both the sternum and the dorsal spine, connected by a structural bridge of nylon or webbing. This architecture allows handlers to split tensile load across multiple skeletal points. During initial movement phases, the front ring absorbs primary redirection forces, while the rear ring maintains stability. This dual-point distribution prevents excessive twisting in dogs with high structural asymmetry or joint dysplasia, balancing mechanical redirection with skeletal protection. Handlers can clip a double-ended lead to both points, transitioning control dynamically depending on environmental arousal levels and spatial requirements.
Cranial Halter Convergence
Harnesses that incorporate head halters or muzzle-style facial loops operate on a different physical principle: cranial steering. By applying mild pressure around the muzzle and behind the ears, these systems exploit the mammalian cervical-cranial axis. Because a dog's center of mass follows the direction of its head, rotating the cranial axis redirects the entire body mass with minimal mechanical effort. This approach trades force redirection for directional control, though it requires specific habituation protocols to prevent stress responses associated with facial restriction. Handlers must introduce cranial equipment gradually using positive reinforcement to avoid aversion conditioning.
The Kinetic Cost Function of Torque and Fulcrum Dynamics
Evaluating the efficiency of any anti-pull system requires analyzing torque generation. Torque equals force multiplied by distance from the pivot point. When a leash attaches to the upper back, the moment arm between the dog's center of gravity and the attachment point is minimal, but the forward surge creates a high-torque rotational vector that lifts the handler's center of mass.
Shifting the attachment point to the ventral sternum alters the moment arm. The pulling force now acts against the dog's own turning radius. Instead of acting as a linear engine, the dog experiences an internal torque imbalance whenever tension spikes. The mechanical advantage shifts from the animal to the handler. A ninety-pound dog pulling against a dorsal harness generates significant linear force, whereas the same dog pulling against a sternum-mounted redirect experiences immediate lateral disruption, reducing effective propulsion by up to seventy percent without requiring proportional human muscle output.
Furthermore, this mechanical advantage shifts the energetic expenditure. In a traditional setup, the dog expends minimal energy to overcome the handler's static resistance because body weight provides the primary engine. In a sternum-redirect setup, the dog's own forward energy destabilizes its footing, increasing the cognitive and physical cost of pulling.
Operational Protocols for Behavioral Integration
Hardware alone cannot rewrite operant conditioning pathways. Equipment serves as a physical circuit breaker, interrupting unwanted momentum while the handler implements structured training sequences.
The first operational phase involves establishing a slack-leash threshold. When tension registers on the line, forward movement must cease instantly. The handler acts as an immovable anchor, rendering the dog's pulling behavior entirely ineffective at achieving spatial goals. This eliminates the intermittent reinforcement schedule inherent in loose walking where pulling sometimes succeeds in reaching a destination.
The second phase incorporates rate-of-reinforcement pacing. High-value rewards are delivered at the precise spatial coordinate where the dog's shoulder aligns with the handler's leg. This conditions the animal to associate proximity with primary reinforcement, shifting the internal motivation structure from environmental foraging to handler-proximate orientation.
The third phase introduces environmental distraction gradients. Training begins in low-stimulus indoor spaces and systematically scales to complex outdoor environments containing high-arousal triggers such as wildlife or passing vehicles. Transitioning across these gradients prevents behavioral regression when physiological arousal levels spike. Without this systematic progression, animals display context-dependent obedience, performing well in sterile environments while defaulting to opposition pulling in high-stimulus zones.
Equipment Selection Variables and Trade-Off Friction
Every hardware choice introduces specific trade-off friction that operators must manage during selection and deployment.
- Material rigidity determines structural longevity versus chafing risk. High-tensile nylon offers exceptional durability under high-load conditions but can cause friction burns in short-coated breeds if the webbing edges lack binding or padding.
- Strap placement geometry dictates range of motion. Designs that cross directly over the shoulder joint restrict the scapular extension phase of the canine stride, potentially altering gait mechanics over extended periods. Y-front configurations maintain unobstructed shoulder rotation while keeping the sternum ring securely centered.
- Hardware weight impacts small-breed ergonomics. Heavy metal D-rings and thick buckles appropriate for working-line breeds can cause fatigue and postural compensation in toy-group specimens, necessitating lightweight aluminum or composite hardware alternatives.
- Breathability and thermal retention affect extended wear tolerance in working environments. Dense neoprene paddings trap body heat, requiring mesh alternatives in high-temperature operating conditions.
Operators must audit their specific operational constraints—animal body morphology, handler physical capacity, and environmental exposure—to select equipment that optimizes mechanical redirection while minimizing physiological restriction.
Strategic Deployment Matrix
Effective canine traction management relies on matching equipment mechanics to the specific behavioral phenotype of the animal.
For high-drive working breeds exhibiting intense forward momentum and rapid acceleration, sternum-redirect harnesses paired with fixed-length, non-retractable lines provide the highest degree of kinetic control. Retractable leads should be systematically eliminated from operational use, as their constant low-level tension trains the animal to maintain continuous pull pressure, negating the neurological clarity required for loose-leash conditioning.
For reactive dogs prone to sudden flight responses or lunging triggers, dual-clip systems offer a balanced compromise, absorbing peak shock loads across both chest and back while retaining emergency steering capacity.
Long-term behavioral success depends on treating equipment as a temporary force-mitigation tool rather than a permanent behavioral cure. Hardware provides the physical window of opportunity; structured operational consistency establishes the permanent neural pathway. Transitioning away from specialized redirection gear becomes viable only once intrinsic impulse control and spatial awareness are fully ingrained in the animal's operational baseline.